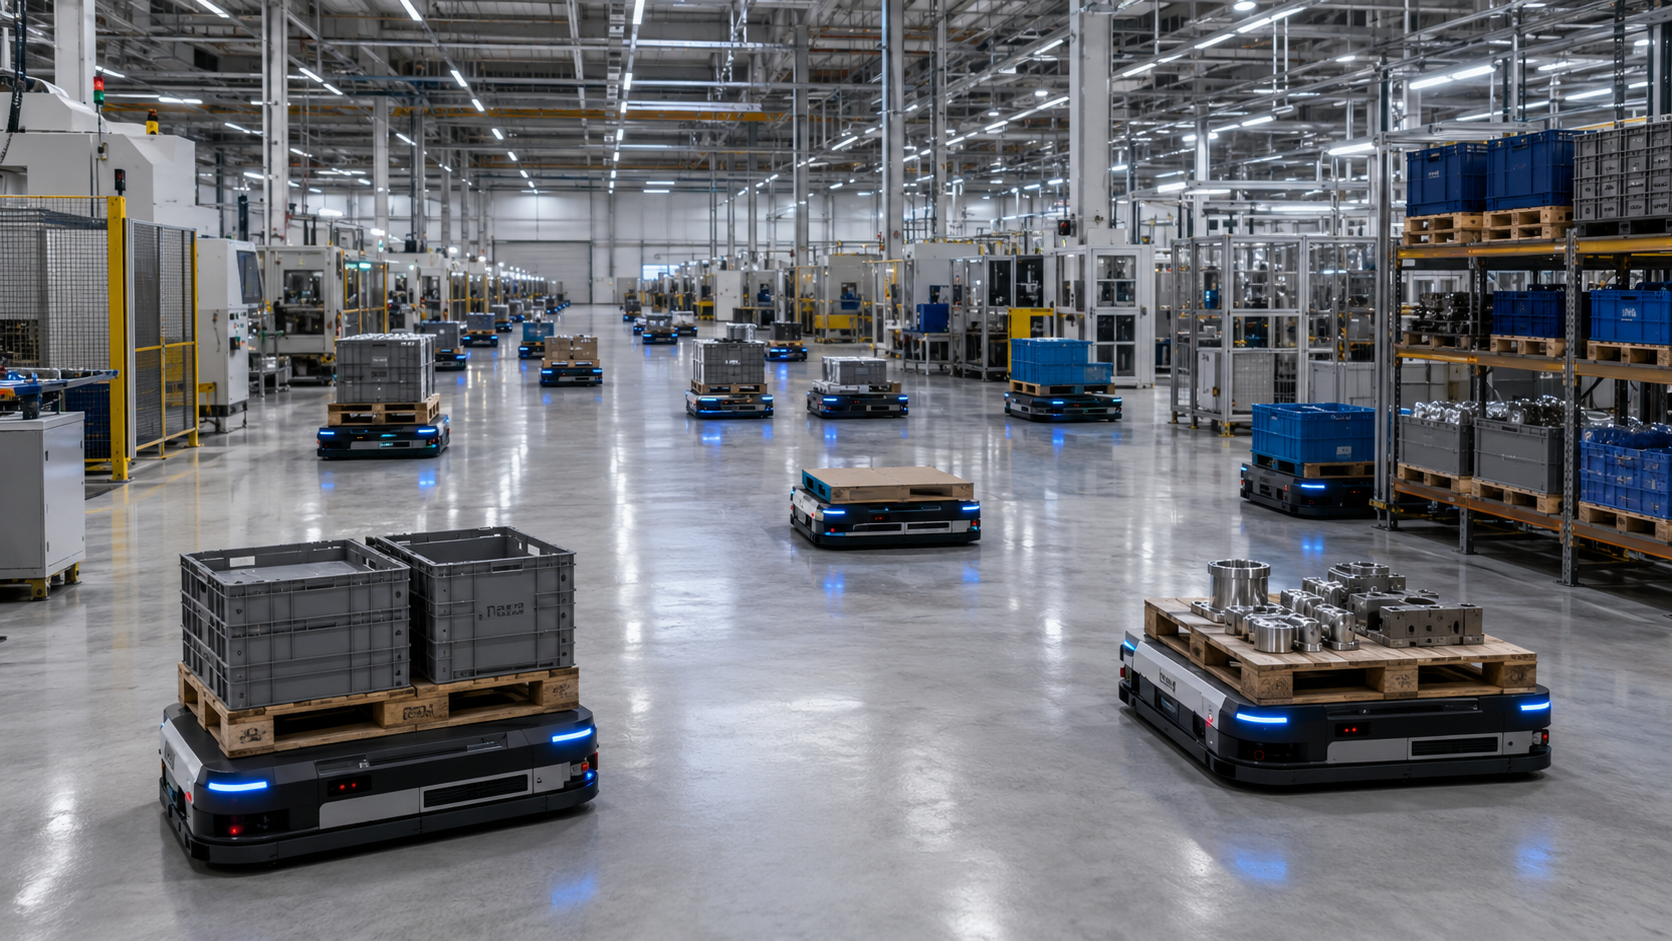
Artificial intelligence is rapidly changing what robots can do.
But there is a more fundamental constraint that AI alone cannot solve:
energy.
Autonomous Mobile Robots (AMRs) and Automated Guided Vehicles (AGVs) can navigate more intelligently, coordinate more effectively and make increasingly sophisticated decisions. Yet most mobile robots still depend on an energy model built around interruption: work, stop, charge, return.
As robotic fleets scale, that interruption becomes an operational constraint.
The next major improvement in mobile robotics may therefore come not only from making robots smarter, but from changing how they receive power.
Mobile robotics is scaling fast
The shift toward autonomous robotics is already visible in global deployment data.
According to the International Federation of Robotics (IFR), global shipments of professional service robots increased 24% in 2025 to almost 250,000 units.
Transportation and logistics was the largest application category, with approximately
117,500 robots sold in 2025, up 21% year over year and representing
47% of professional service robot sales reported by IFR.
That growth matters.
As mobile robot fleets become larger and more important to production and logistics, the infrastructure supporting them becomes increasingly important too.
Navigation, fleet orchestration and AI may determine where a robot should go.
Energy determines whether it can keep going.
Why is charging downtime a problem for AMRs and AGVs?
Traditional
mobile robot energy management is based on a cycle:
Operate → stop → charge → return to operation.
Some systems improve this through opportunity charging, faster charging or intelligent fleet scheduling.
These approaches can improve utilization, but they still require operations to accommodate the robot’s need to recharge.
That can introduce several system-level consequences:
- Robots periodically become unavailable for productive work.
- Fleet managers must incorporate battery state into task allocation.
- Charging stations consume infrastructure and floor space.
- Fleet capacity may need to account for robots that are charging rather than working.
- Battery condition becomes an operational variable that must be continuously managed.
The problem becomes increasingly important as automation scales because a robot fleet is not valuable simply because it exists.
It is valuable when it is productive.
What if robots received energy as part of the workflow?
This is the principle behind
Power-in-Motion.
Instead of treating charging as a separate activity, energy can be delivered at selected points along the routes robots already travel.
A robot does not have to leave the workflow simply to obtain energy.
That changes the question from:
“How quickly can we recharge the robot?”
to:
“Why should receiving energy require the robot to stop working?”
This distinction is fundamental.
Faster charging optimizes the interruption.
Power-in-Motion is designed to remove the interruption.
What is CaPow’s Genesis Power-in-Motion system?
CaPow’s Genesis platform is designed to deliver energy to mobile robots during their normal operating cycle.
The system combines strategically positioned transmitter antennas with a receiver installed on the robot. As the robot moves across an energized section of its existing route, it can receive power without being sent to a dedicated charging location.
Genesis is designed as a modular
infrastructure layer for mobile robotics rather than as a charger tied to one specific robot.
According to CaPow’s published technical specifications, the current Genesis platform is rated at
500 W, supports
12-60 V DC output, up to
30 A, and energy-transfer efficiency of up to
88%. It supports dynamic movement at speeds of up to
5 m/s, with a lock-in time of approximately
10 milliseconds.
This allows energy delivery to become part of the robot’s operating environment rather than a separate destination.
One energy infrastructure layer can support different robots
Modern factories and warehouses are increasingly heterogeneous.
A facility may use different AMRs or AGVs for different applications, payloads and workflows. Over time, robot platforms may also change.
That raises an important infrastructure question:
Should the energy system be locked to a specific robot platform?
At
MODEX 2026, CaPow demonstrated an
Ocado Chuck and a MiR600 receiving energy from the same Genesis Power-in-Motion platform.
The significance goes beyond interoperability.
It demonstrates the possibility of treating energy as a common infrastructure layer across different mobile robotic systems.
The robot can change.
The workflow can evolve.
The energy layer does not necessarily have to be redesigned around every individual robot platform.
Real-world operations show why energy architecture matters
The impact of charging is not only theoretical.
In a published CaPow
case study involving a Tier 1 automotive manufacturer operating a 50-robot fleet, charging downtime contributed to inflated fleet requirements and operational inefficiency. The manufacturer reported automation-related losses representing 4% of production before implementing Power-in-Motion.
Following deployment of Genesis, the manufacturer reported eliminating charging downtime and reallocating robots that had previously been required to compensate for that lost availability.
The lesson is broader than one deployment.
When robots stop for energy, the cost is not limited to electricity or charging equipment.
It can affect
fleet utilization, throughput, infrastructure requirements and overall automation economics.
Energy is becoming a software problem too
Modern robotics infrastructure is increasingly software-defined.
Energy should be no different.
CaPow’s Genesis Energy Management System (GEMS), introduced at CES 2026, adds a software layer to Power-in-Motion infrastructure.
GEMS provides capabilities including real-time energy telemetry, operational insights, fault information, remote support and proactive maintenance.
That creates another important shift.
Instead of energy being something operators manage primarily through battery state and charging schedules, it can become an observable and manageable operational resource.
In an AI-driven operation, this matters.
AI can optimize routing.
AI can optimize task assignment.
AI can predict demand.
But if energy remains an external constraint that periodically removes robots from productive operation, there is still a physical bottleneck underneath the intelligence.
Does Power-in-Motion eliminate batteries?
Not necessarily.
The more immediate opportunity is to change the role the battery plays.
Instead of designing an operation around storing enough energy for long periods between charging events, energy can be replenished incrementally during normal activity.
That opens the possibility of reducing dependence on large onboard energy reserves and designing the overall system around continuous energy availability rather than periodic recovery.
In other words, the objective is not simply a better battery.
It is a better energy architecture.
What is the difference between stationary charging, opportunity charging and Power-in-Motion?
Stationary charging requires the robot to stop at a dedicated charging location.
Opportunity charging uses available idle periods to replenish the battery, but the robot still needs to engage with charging infrastructure.
Power-in-Motion delivers energy at selected points within the robot’s normal operating path, allowing energy transfer to occur without creating a dedicated charging task.
That distinction becomes increasingly important as facilities move toward higher robot utilization and increasingly continuous operations.
The next robotics bottleneck may not be intelligence
The robotics industry has spent years improving perception, navigation, autonomy and fleet orchestration.
Those advances are essential.
But the physical infrastructure underneath autonomous systems matters just as much.
The IFR’s latest data shows that mobile robotics for transportation and logistics is already operating at significant global scale.
As that installed base grows, the industry will increasingly have to address a simple question:
Can the energy architecture scale as efficiently as the intelligence?
CaPow believes mobile robots should not have to choose between working and receiving energy.
With Power-in-Motion, energy becomes part of motion itself.
And that creates a different vision for autonomous operations:
Smarter robots. Continuous energy. Continuous productivity.